This part is for members
Membership opens soon. Leave your email and we'll tell you the day it does. Founding members get the launch price.
Keep watching the free partsFoundations · 4
From Simulink model to generated code
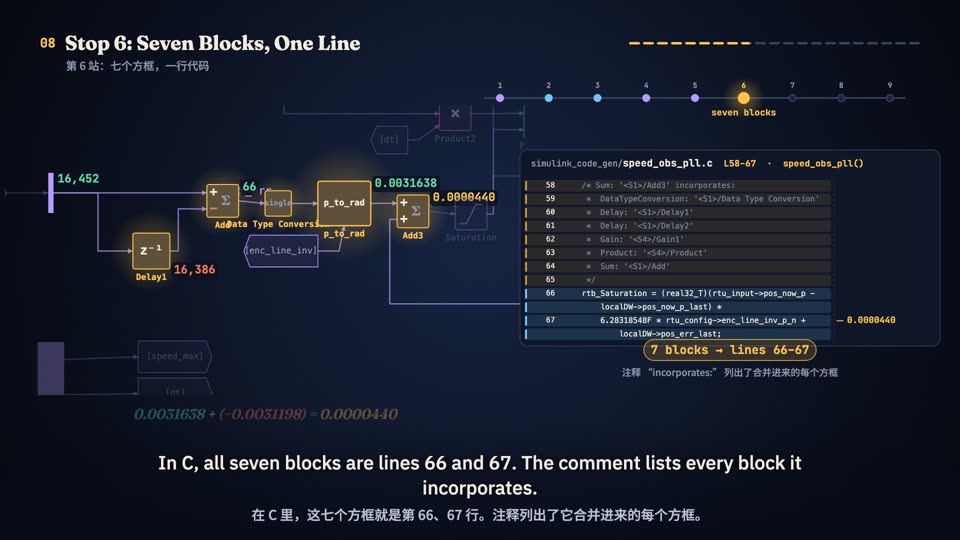
One call of the speed observer through nine stops: call 500 of the PP move, 50 ms in, position 16452 in, 31.368 rad/s out. The diagram is drawn straight from the XML inside the .slx; the rtu_/rty_/rtb_ prefixes, the <S1>/Add3 paths in the comments, seven blocks folded into one line, Delay blocks becoming the DW struct. Then the diagram itself is run: with fused multiply-add off it matches the generated C bit for bit on all 10,000 calls. Last, a pitfall: with an unseeded state the first output is 3638 rad/s from a motor that is not moving.