Courses
Robotics now, AI agents next. Every part is real source and real runs.
22 of 22 parts
Robotics · CourseServoHub From Zero22 parts out · 3.4 h of videoCourse page → Free3:45
1a · OverviewServoHub From Zero
Opening: what this course is
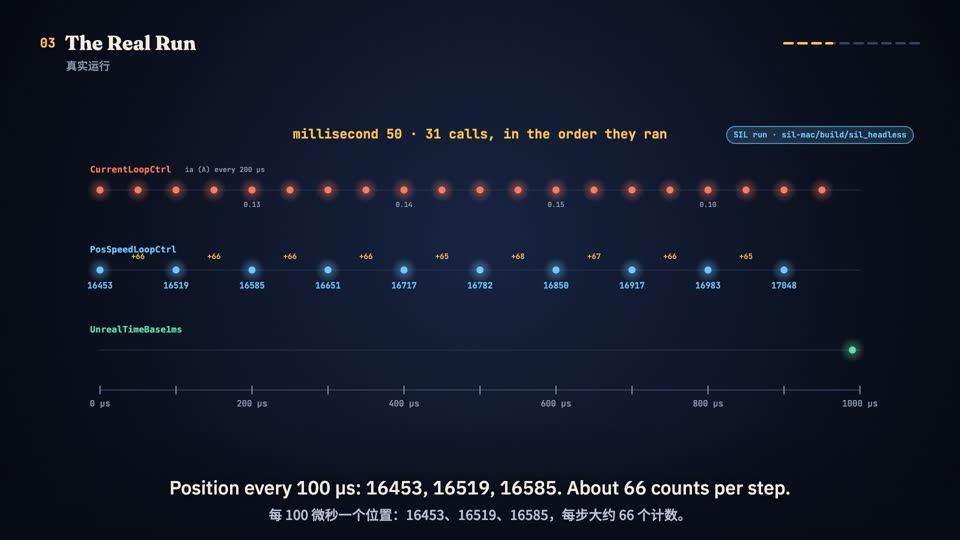
 Free6:31
1b · OverviewServoHub From Zero
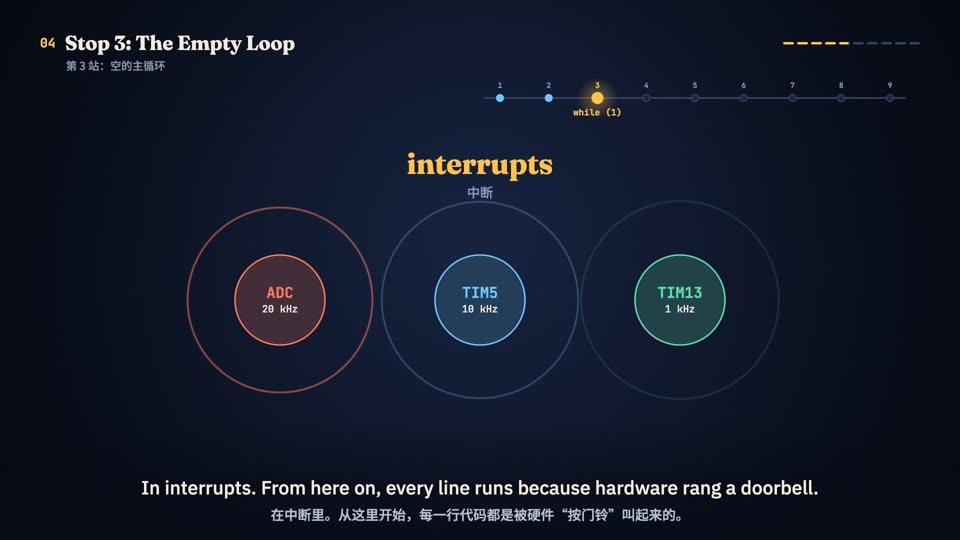
The Big Map 1: from power-on to the two control loops
 Free5:48
1c · OverviewServoHub From Zero
The Big Map 2: who interrupts whom, and how the loops talk
 Free with account8:28
2 · FoundationsServoHub From Zero
Running ServoHub on a Mac: SIL simulation
 10:09
3 · FoundationsServoHub From Zero
The whiteboard kAxis: who may write it, and through which door
 12:27
4 · FoundationsServoHub From Zero
From Simulink model to generated code
 9:01
5a · FoundationsServoHub From Zero
BSP 1: one tick across the seam
 11:03
5b · FoundationsServoHub From Zero
BSP 2: after the PWM switches off
 9:39
5c · FoundationsServoHub From Zero
BSP 3: when the bus voltage falls
 8:37
5d · FoundationsServoHub From Zero
BSP 4: asking for more than the board gives
 7:09
6a · SkeletonServoHub From Zero
Four gates 1: waiting for the bus
 7:32
6b · SkeletonServoHub From Zero
Four gates 2: interrupts on, then the encoder
 7:59
6c · SkeletonServoHub From Zero
Four gates 3: calibrate, then open
 6:32
6d · SkeletonServoHub From Zero
Four gates 4: one tick late
 7:29
6e · SkeletonServoHub From Zero
Four gates 5: who interrupts whom
 11:36
7a · SkeletonServoHub From Zero
Current sampling 1: when in the PWM period
 12:33
7b · SkeletonServoHub From Zero
Current sampling 2: from ADC count to amps
 New9:54
8a · SkeletonServoHub From Zero
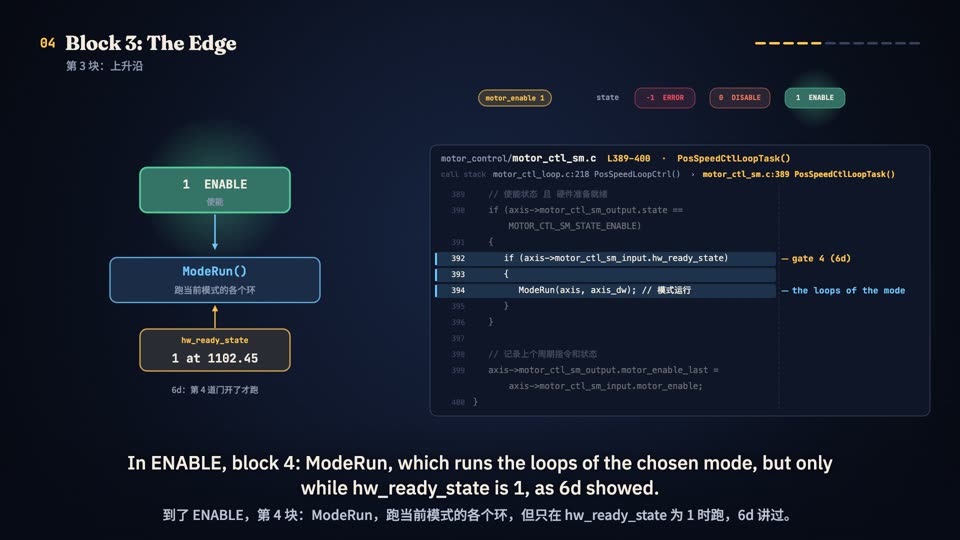
Two state machines 1: rising edge
 18:50
11a · SensorsServoHub From Zero
Encoders 1: how one frame becomes an angle (Tamagawa)
 18:59
11b · SensorsServoHub From Zero
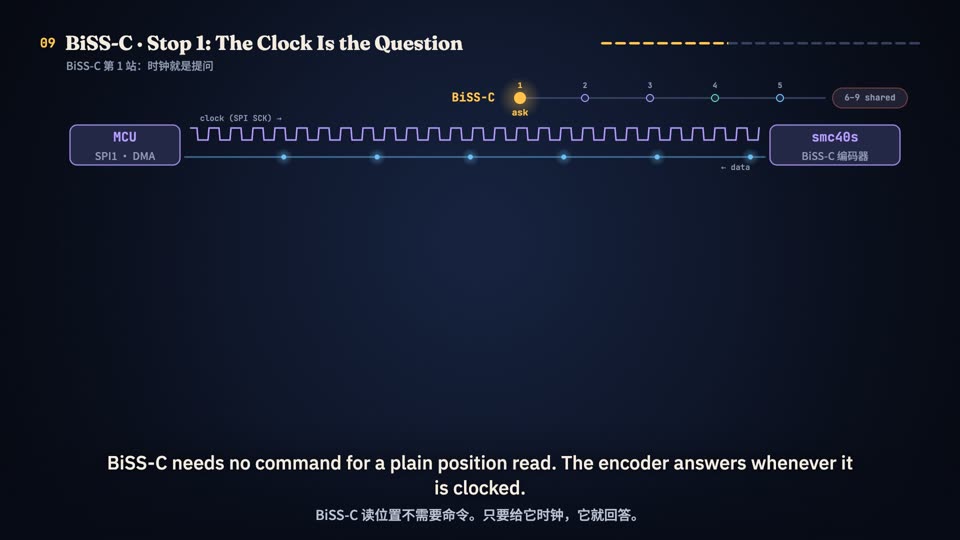
Encoders 2: the other three wires (MT68xx · BiSS-C · ABZ)
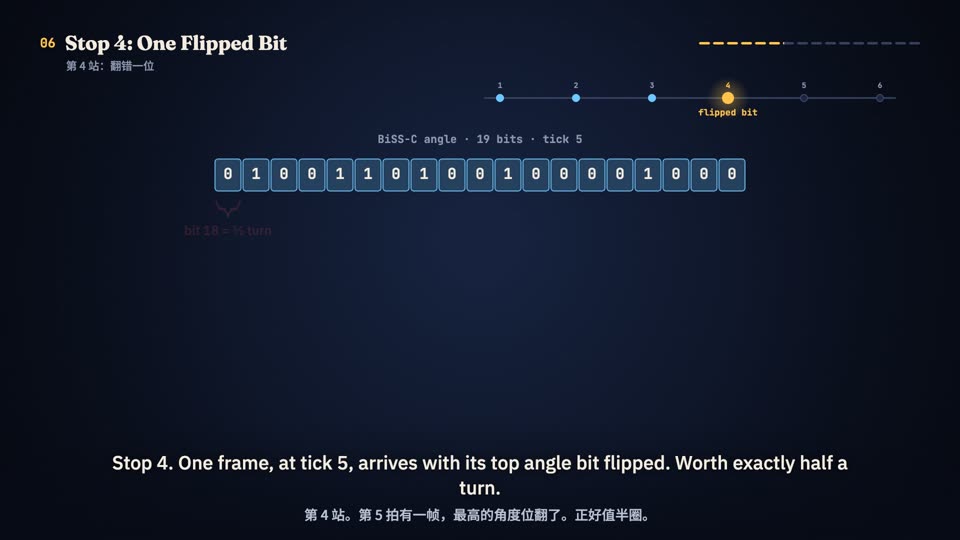 8:24
11c · SensorsServoHub From Zero
Encoders 3: when the data goes bad
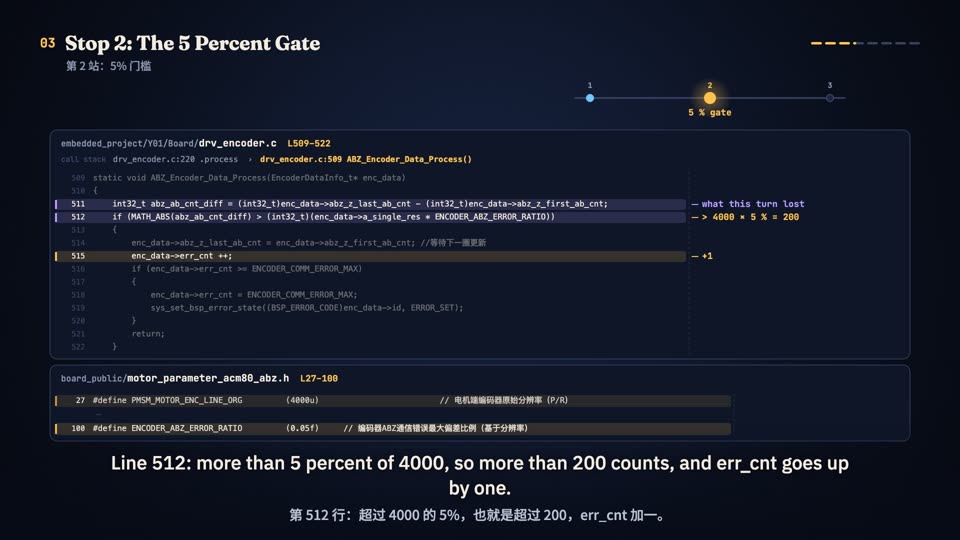 4:08
11d · SensorsServoHub From Zero
Encoders 4: lost ABZ pulses